A chart gives a depth as though it were a property of one fixed spot. The survey vessel that supplied it was moving; the water surface was moving too. Between the instrument and the bottom lay a column of water whose temperature and salinity could change the path of sound. A useful depth begins with an echo, but it takes more than an echo to place a number on a chart.
An echo sounder sends out a pulse and measures how long it takes for a return to arrive. Sound has made a journey down and back, so a simple straight-down calculation uses half the travel time and a value for the speed of sound in water. This is the first translation: elapsed time becomes distance. It is also the first place where an apparently exact reading can go wrong. The calculation depends on the water the pulse actually crossed, not on a permanent speed assigned to “the sea.” NOAA's 2018 hydrographic specifications require sound-speed observations and corrections because depth is computed from travel time and speed.
A line of depths, then a swath
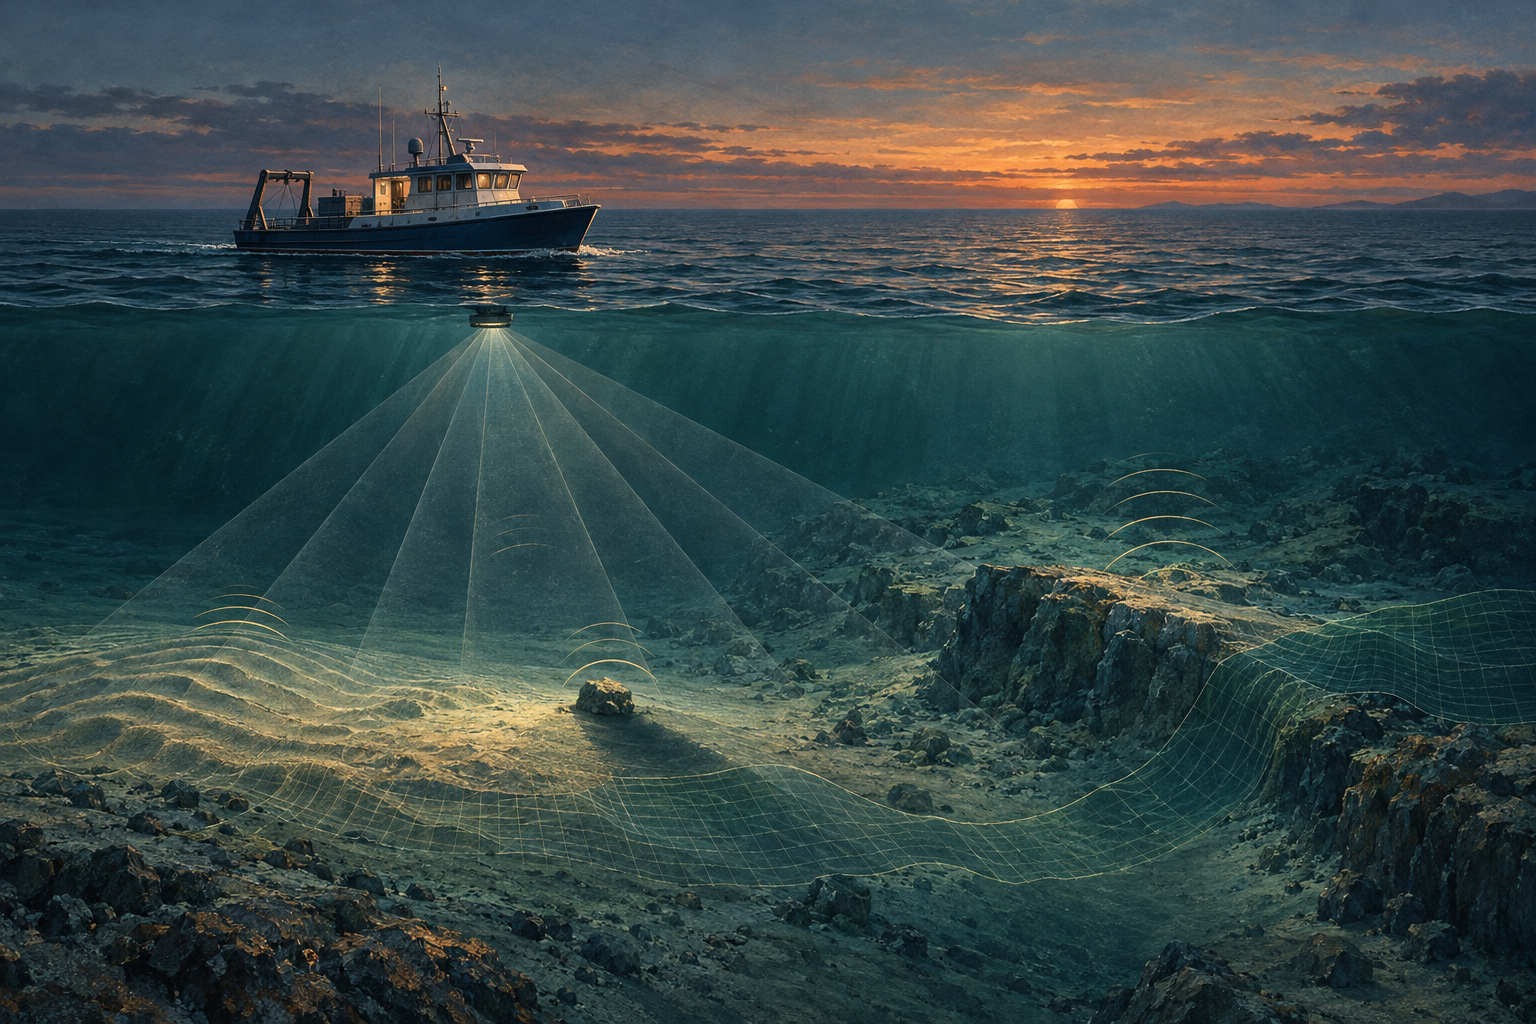
A single-beam echo sounder looks chiefly beneath the vessel. As the boat travels, it leaves a sequence of soundings along its track, much like a line drawn across a blank page. That line can be valuable: it may check a known feature or provide depths where a wider system cannot work. Yet the spaces between widely separated tracks are still spaces between measurements. NOAA's field procedures manual describes both single-beam and multibeam systems as tools for acquiring bathymetry, with different ways of gathering the returns.
A multibeam echo sounder forms many beams across the vessel's path. For each ping, it measures the angle and two-way travel time of returns from a fan-shaped swath. A vessel running a planned series of adjacent lines can therefore cover an area with many more soundings than a single narrow track would provide. The advantage is coverage, not a magical exemption from survey design. Lines must be spaced and checked so that a shallow obstruction does not sit in a gap. Even within a swath, the footprint of a beam and the spacing of returns change with beam angle and water depth; the far edge does not carry identical detail to the strip directly under the vessel. The NOAA manual describes those differences in beam spacing, while the International Hydrographic Organization's S-44 standard sets coverage and feature-detection requirements according to a survey's intended use.
The return also needs a position. A sonar head is mounted below the vessel's reference point, and a vessel rolls, pitches, heaves and changes heading. Its positioning system has its own timing and uncertainty. Survey processing brings those observations into the same instant as each ping, applies sensor offsets and motion corrections, and then relates the depth to a stated vertical reference. The water level that a vessel happened to float on is not, by itself, the chart datum. The IHO requires depths to be reduced to a defined vertical reference frame; its standard also asks that horizontal and vertical uncertainty be recorded with the data. A depth without its reference is a number that cannot be safely compared with another one. IHO S-44
The water bends the ruler
Sound speed varies with temperature, salinity and pressure. Survey crews therefore measure a profile through the water column, rather than assuming that one reading at the surface describes every layer below. NOAA's 2018 specifications call for profiles frequent and extensive enough to correct the survey and for new observations when the water column changes. The field manual also describes using conductivity, temperature and depth observations in multibeam processing.
For a beam aimed outward from a multibeam head, the profile matters twice. Sound speed affects the distance inferred from travel time, and changes in speed along the path refract the beam. A wrong profile can shift an outer sounding sideways as well as vertically. A bottom that looks strangely curled at the edges of overlapping swaths may be asking the processor to inspect the sound-speed correction, not announcing a new ridge. This is a diagnostic possibility, not a rule for every odd shape: motion, positioning and the bottom itself can also be responsible. NOAA's specifications explicitly note both depth and apparent-position effects from an oblique path through changing water.
What the bright patch means
Depth is only one way to read the return. Side-scan sonar sends sound to either side and records the strength of the energy that comes back. Its image can show a change in texture, a hard-looking patch or the dark acoustic shadow cast behind a raised object. It is particularly useful for noticing a possible object that deserves another look. The ordinary side-scan image is an image of backscatter, however, not a direct grid of depths. Some systems acquire colocated bathymetry; the distinction is what the displayed measurement represents. NOAA's field manual treats side-scan imagery separately from bathymetry and describes investigating significant contacts with multibeam or another depth-measuring method.
Nor does a bright return name the material that made it. Strength depends on the seafloor, but also on the angle at which sound arrives, roughness at the scale of the wavelength, the instrument's frequency and the processing. A patch that differs acoustically from its neighbors is a good place to ask a question. It is not a sealed sample bag marked “gravel.” Bryan Costa's 2019 multibeam study used underwater photographs alongside backscatter at several frequencies to test habitat classifications. Its gains were tied to that study's surveyed setting and classes, rather than establishing a universal acoustic signature for each bottom type.
The need to look at the bottom itself is plain in a 2013 Jamaica Bay ground-truth study. Researchers first used multibeam depth and backscatter maps to find contrasting environments, then collected grab samples and underwater images to examine sediment and living cover. The acoustic maps located useful differences; the samples helped say what those differences were. In a separate 2023 USGS data release, investigators likewise paired multibeam-based mapping with sediment grabs, video and water-column measurements at Stellwagen Bank. Neither example makes every unsampled pixel certain. It shows why a map of sound needs carefully chosen points of contact with the material it interprets.
A map that carries its limits
After corrections and review, surveyors turn soundings into a surface. A cell in a bathymetric grid may summarise several returns; elsewhere the surface may have to bridge sparse data. The smooth colour shading that makes a seabed map legible can hide the distinction between a measured point, a processed estimate and an unexamined space. That is why coverage, resolution and uncertainty belong with the map rather than in an afterthought. The IHO's S-44 standard requires uncertainties at a stated confidence level, and a 2024 NOAA report on multibeam uncertainty explains why even the uncertainty metadata attached to gridded products needs care.
Reading a seabed through sound is thus a chain of questions. How long did the echo take? Through what water did it travel? Where and how was the vessel moving? What area did the beams actually cover? Does a bright patch mean a change in texture, an object, or an effect of the viewing angle? Where has anyone brought back a sample or an image? The best survey does not make those questions disappear. It answers them well enough that the next person can use the chart for the purpose it was made to serve, and can see where the answer ends.
A thought worth keeping?